|
Rui Wang (王锐)
I am a Senior Research Scientist at the
Microsoft Spatial AI Lab
in Zurich.
Before joining Microsoft, I pursued my PhD in Computer Science
in the Computer Vision Group
at TUM, where I was advised
by Prof. Daniel Cremers.
In 2018, I did an internship in the Nvidia
Robotics Research Lab in Seattle,
supervised by Prof. Dieter Fox.
In parallel with pursuing my PhD, I also worked as a Senior
Computer Vision Researcher at Artisense,
a startup co-founded by Prof. Cremers. I received my Master from
TUM and my Bachelor from Xi'an Jiaotong University.
My research interests span 3D computer vision, multimodal learning, and on-device AI.
My work encompasses visual recognition, 3D reconstruction, SLAM, and large-scale mapping and localization.
More recently, I have focused on multimodal representations, vision-language models for spatial
understanding and reasoning, and efficient image editing models for on-device deployment.
If you are interested in these topics, feel free to reach out for internship and thesis
opportunities.
Email /
Google Scholar /
LinkedIn /
GitHub /
Homepage@TUM
|
|
|
Technical University of Munich
PhD
Computer Science
2016-2021
|
|
|
Technical University of Munich
Master
Electrical Engineering and Information Technology
2011-2014
|
|
Xi'an Jiaotong University
Bachelor
Automation
2007-2011
|
|
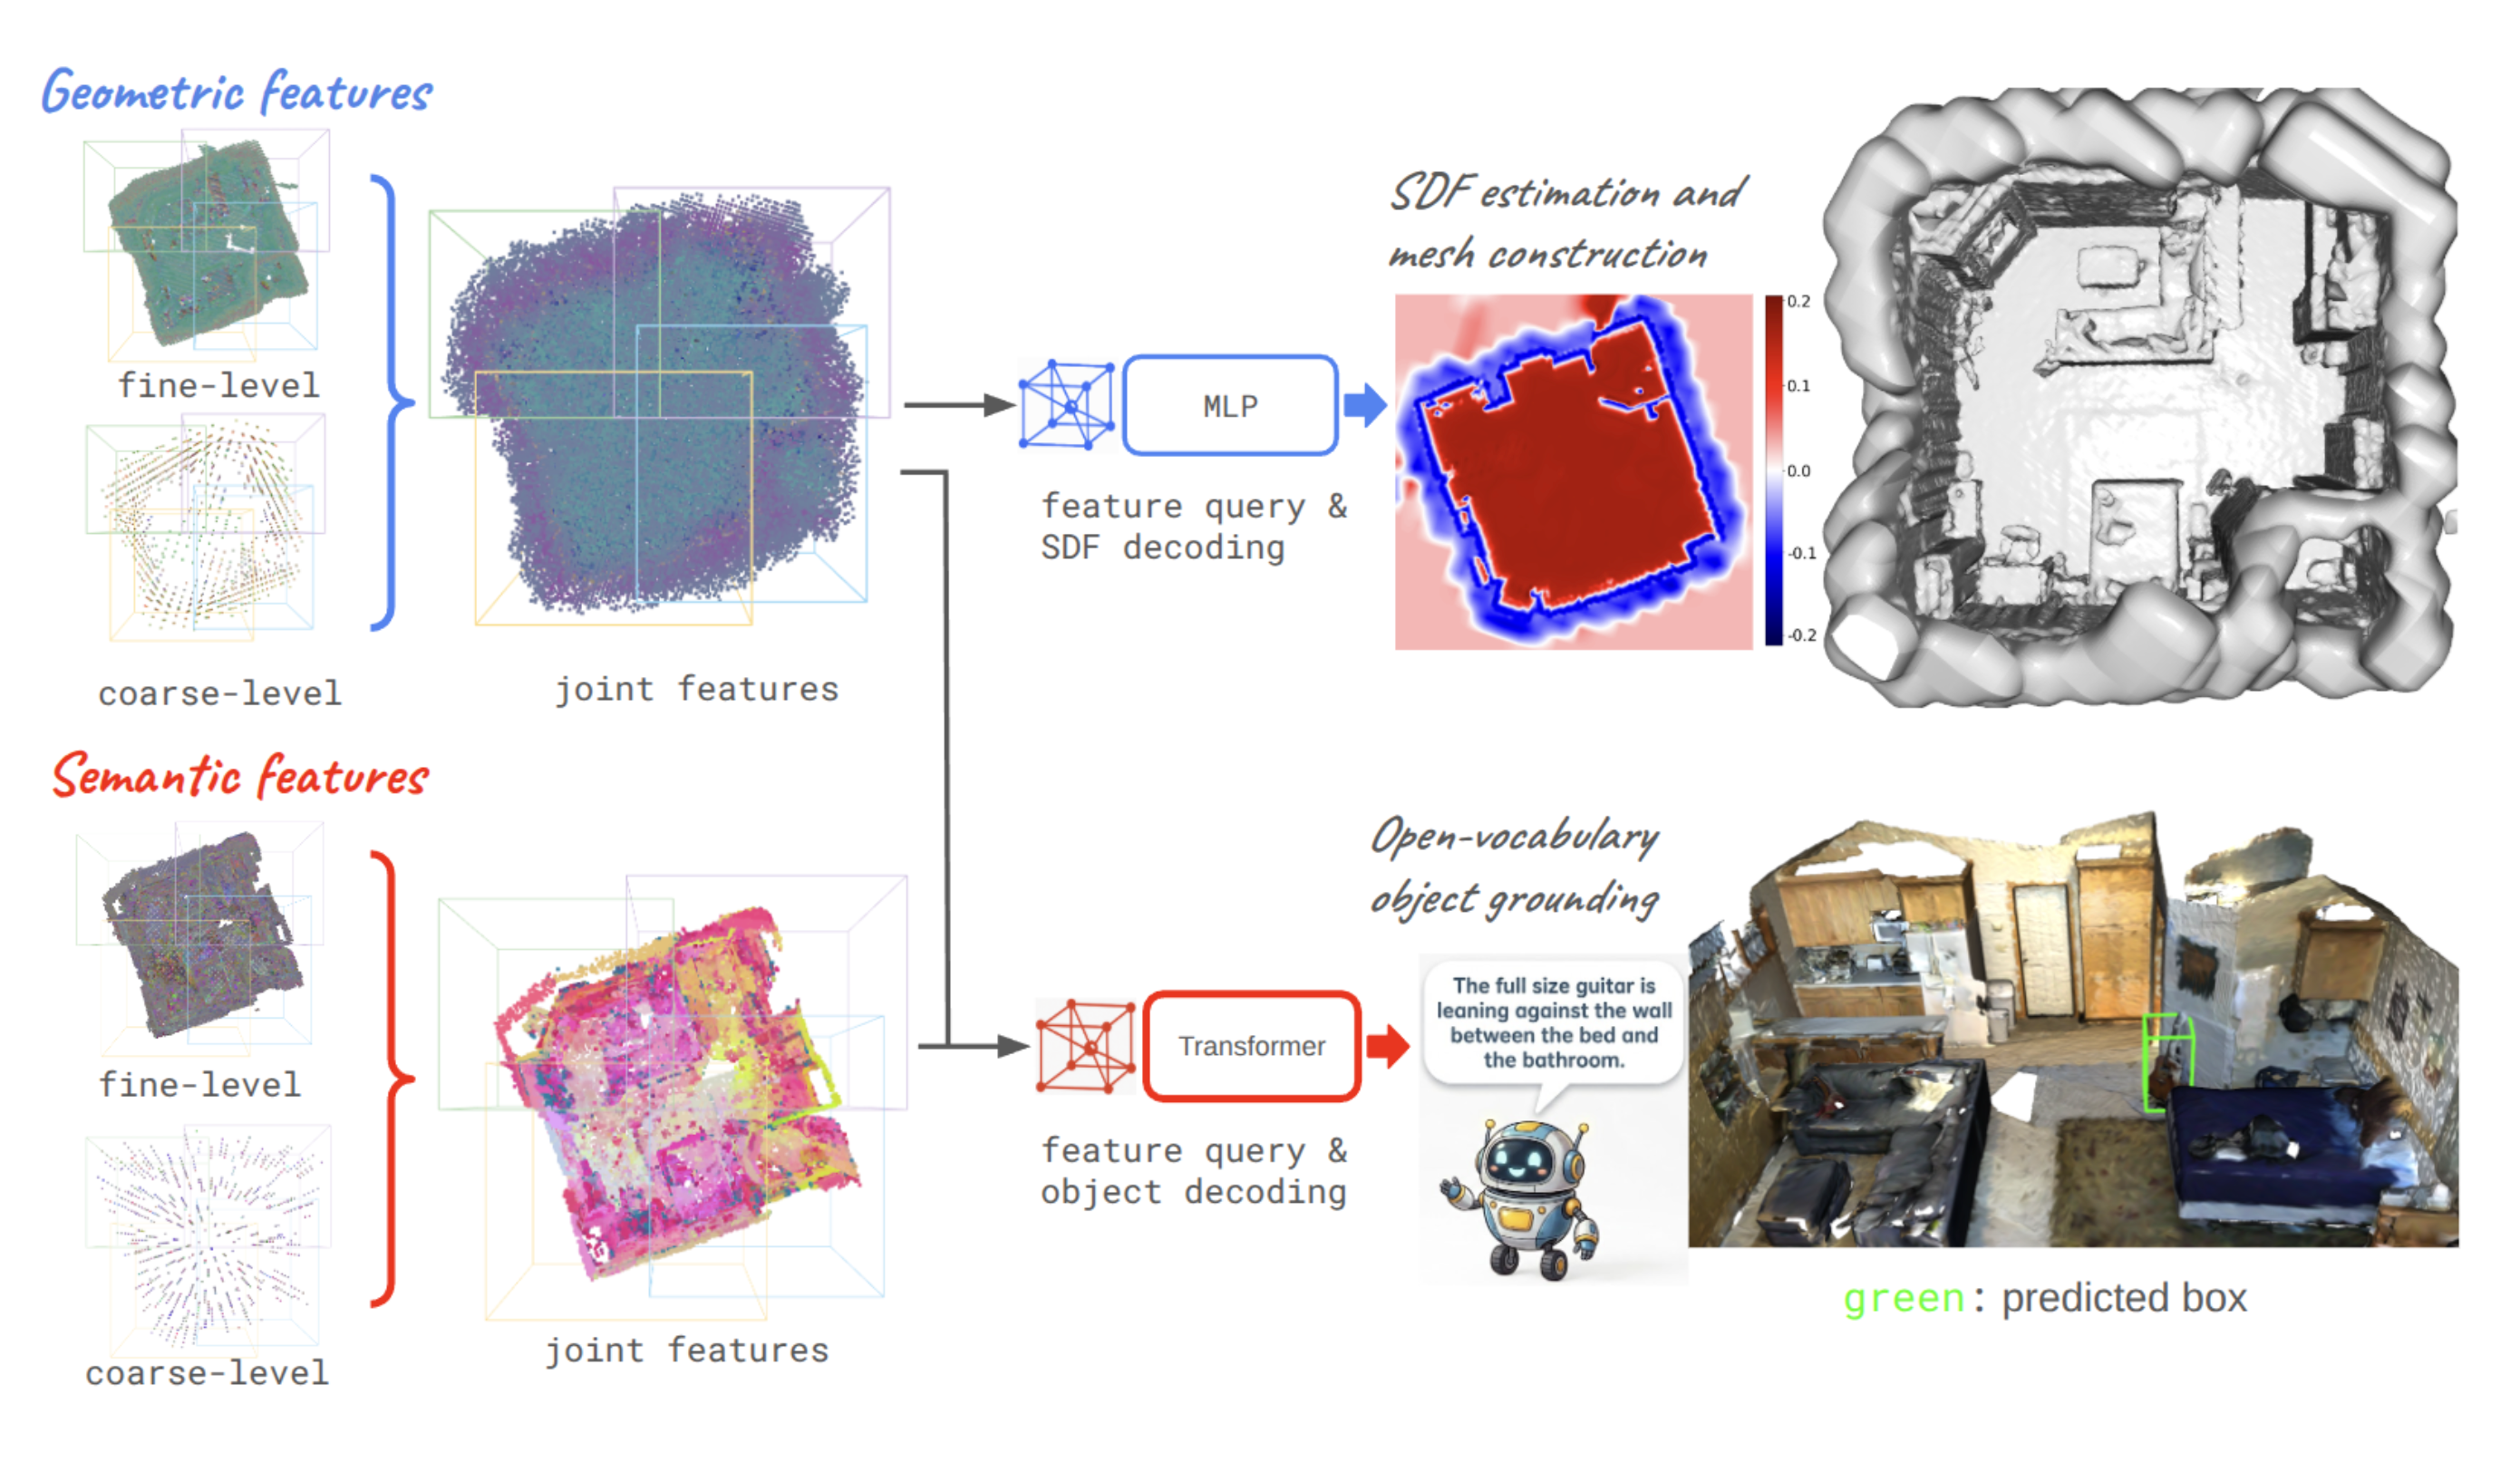
HIGS: Hierarchical Implicit Grids for Joint Geometric and Semantic Scene Understanding
Hanwen Cao, Wenqiang Wu, Kuang-Ting Tu, Mathias Otnes, Jeffrey Delmerico, Rui Wang, Yulun Tian, Nikolay Atanasov
arxiv, 2026
paper |
project page |
code
|
|
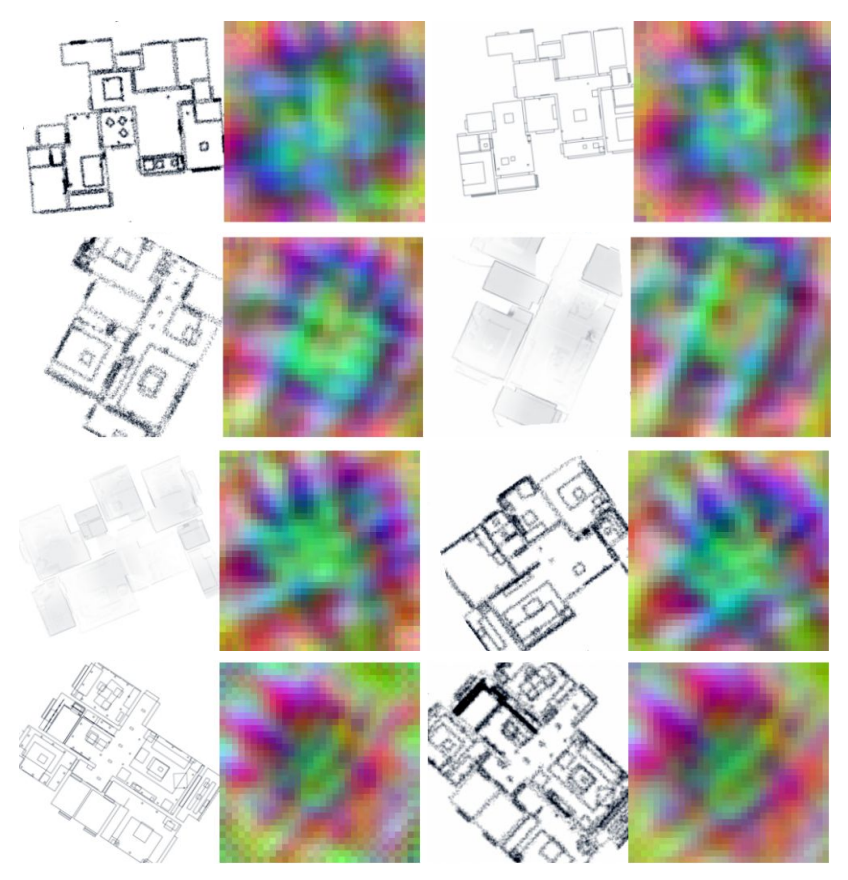
Multimodal Floorplan Encoding: Learning Dense Modality-Invariant Representations
Xavier Anadón, Rémi Pautrat, Rui Wang
ECCV Workshop, 2026
paper
|
|
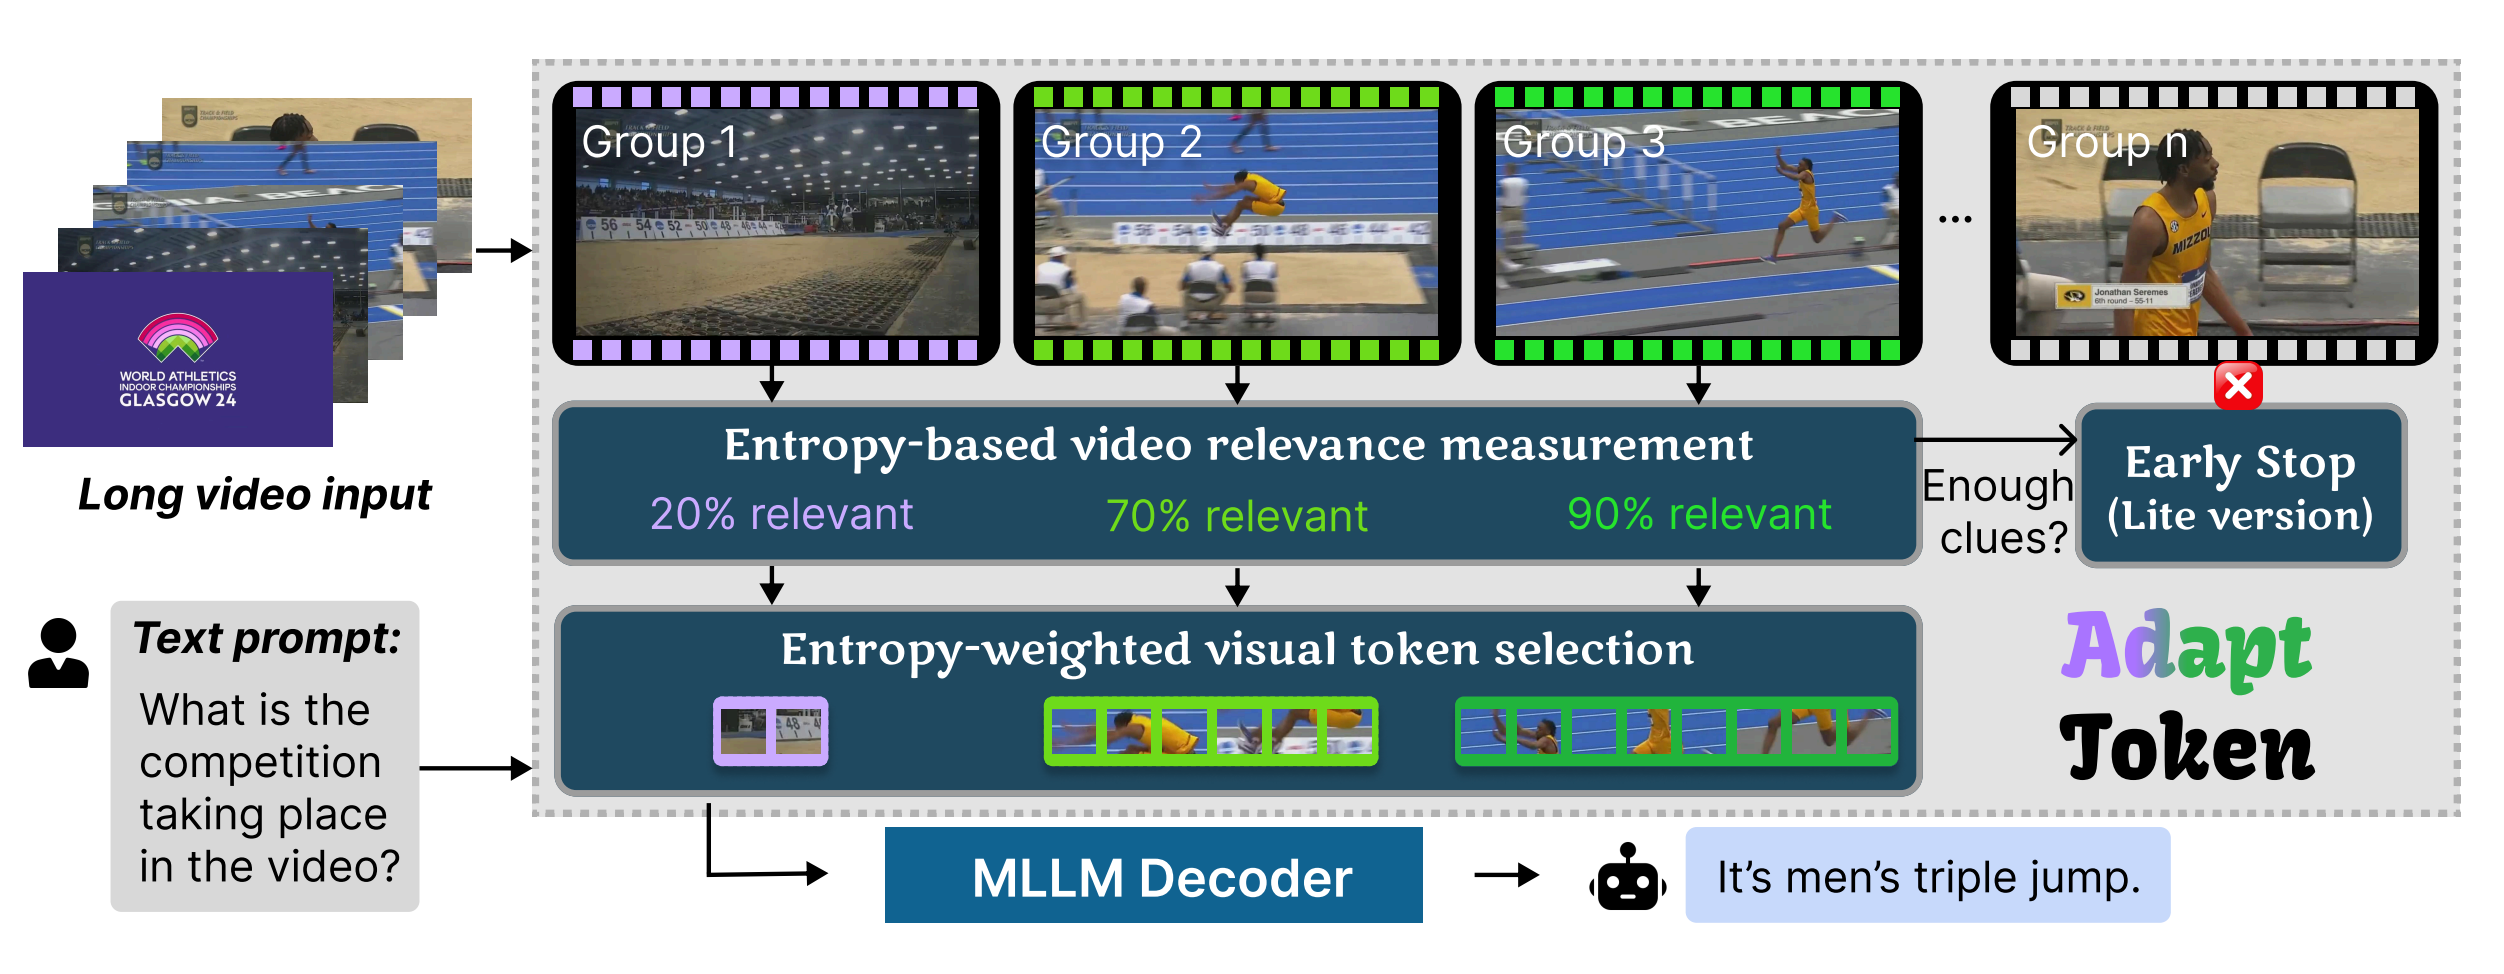
AdaptToken: Entropy-based Adaptive Token Selection for MLLM Long Video Understanding
Haozhe Qi, Kevin Qu, Mahdi Rad, Rui Wang, Alexander Mathis, Marc Pollefeys
arxiv, 2026
paper |
project page |
code
|
|
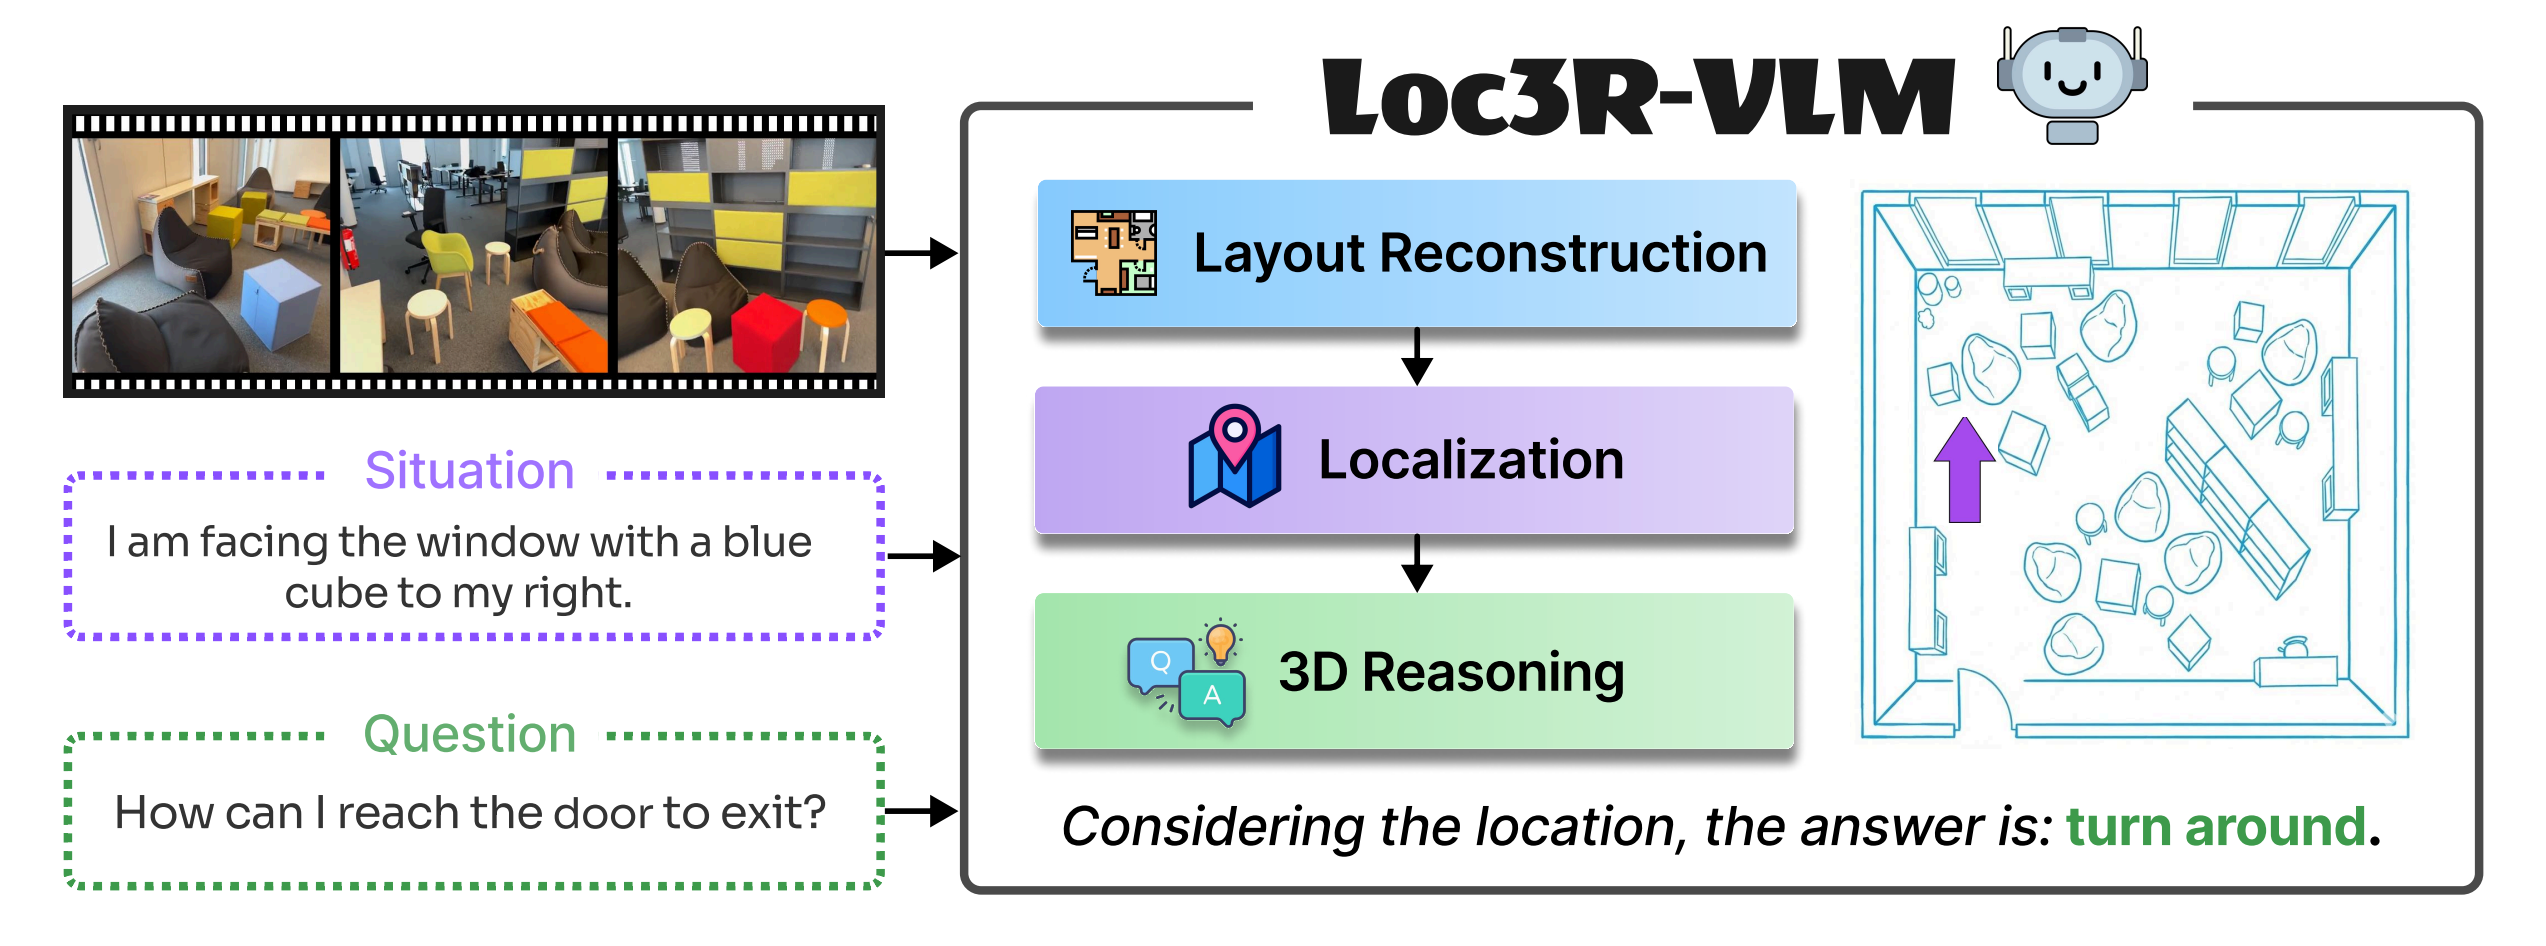
Loc3R-VLM: Language-based Localization and 3D Reasoning with Vision-Language Models
Kevin Qu, Haozhe Qi, Mihai Dusmanu, Mahdi Rad, Rui Wang, Marc Pollefeys
arxiv, 2026
paper |
project page |
code
|
|
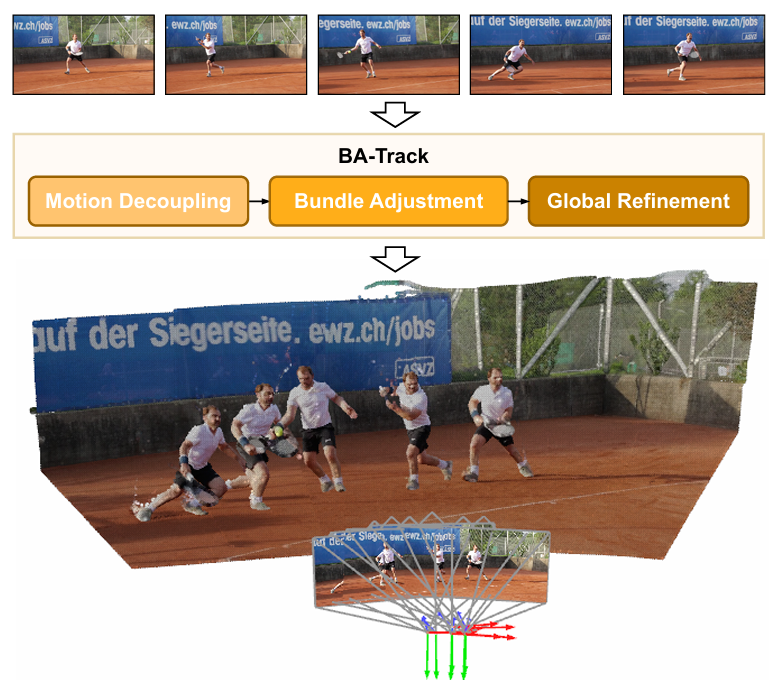
Back on Track: Bundle Adjustment for Dynamic Scene Reconstruction
Weirong Chen, Ganlin Zhang, Felix Wimbauer, Rui Wang, Nikita Araslanov, Andrea Vedaldi,
Daniel Cremers
ICCV, 2025 (Oral Presentation, Award Candidate)
paper |
project page |
code
|
|
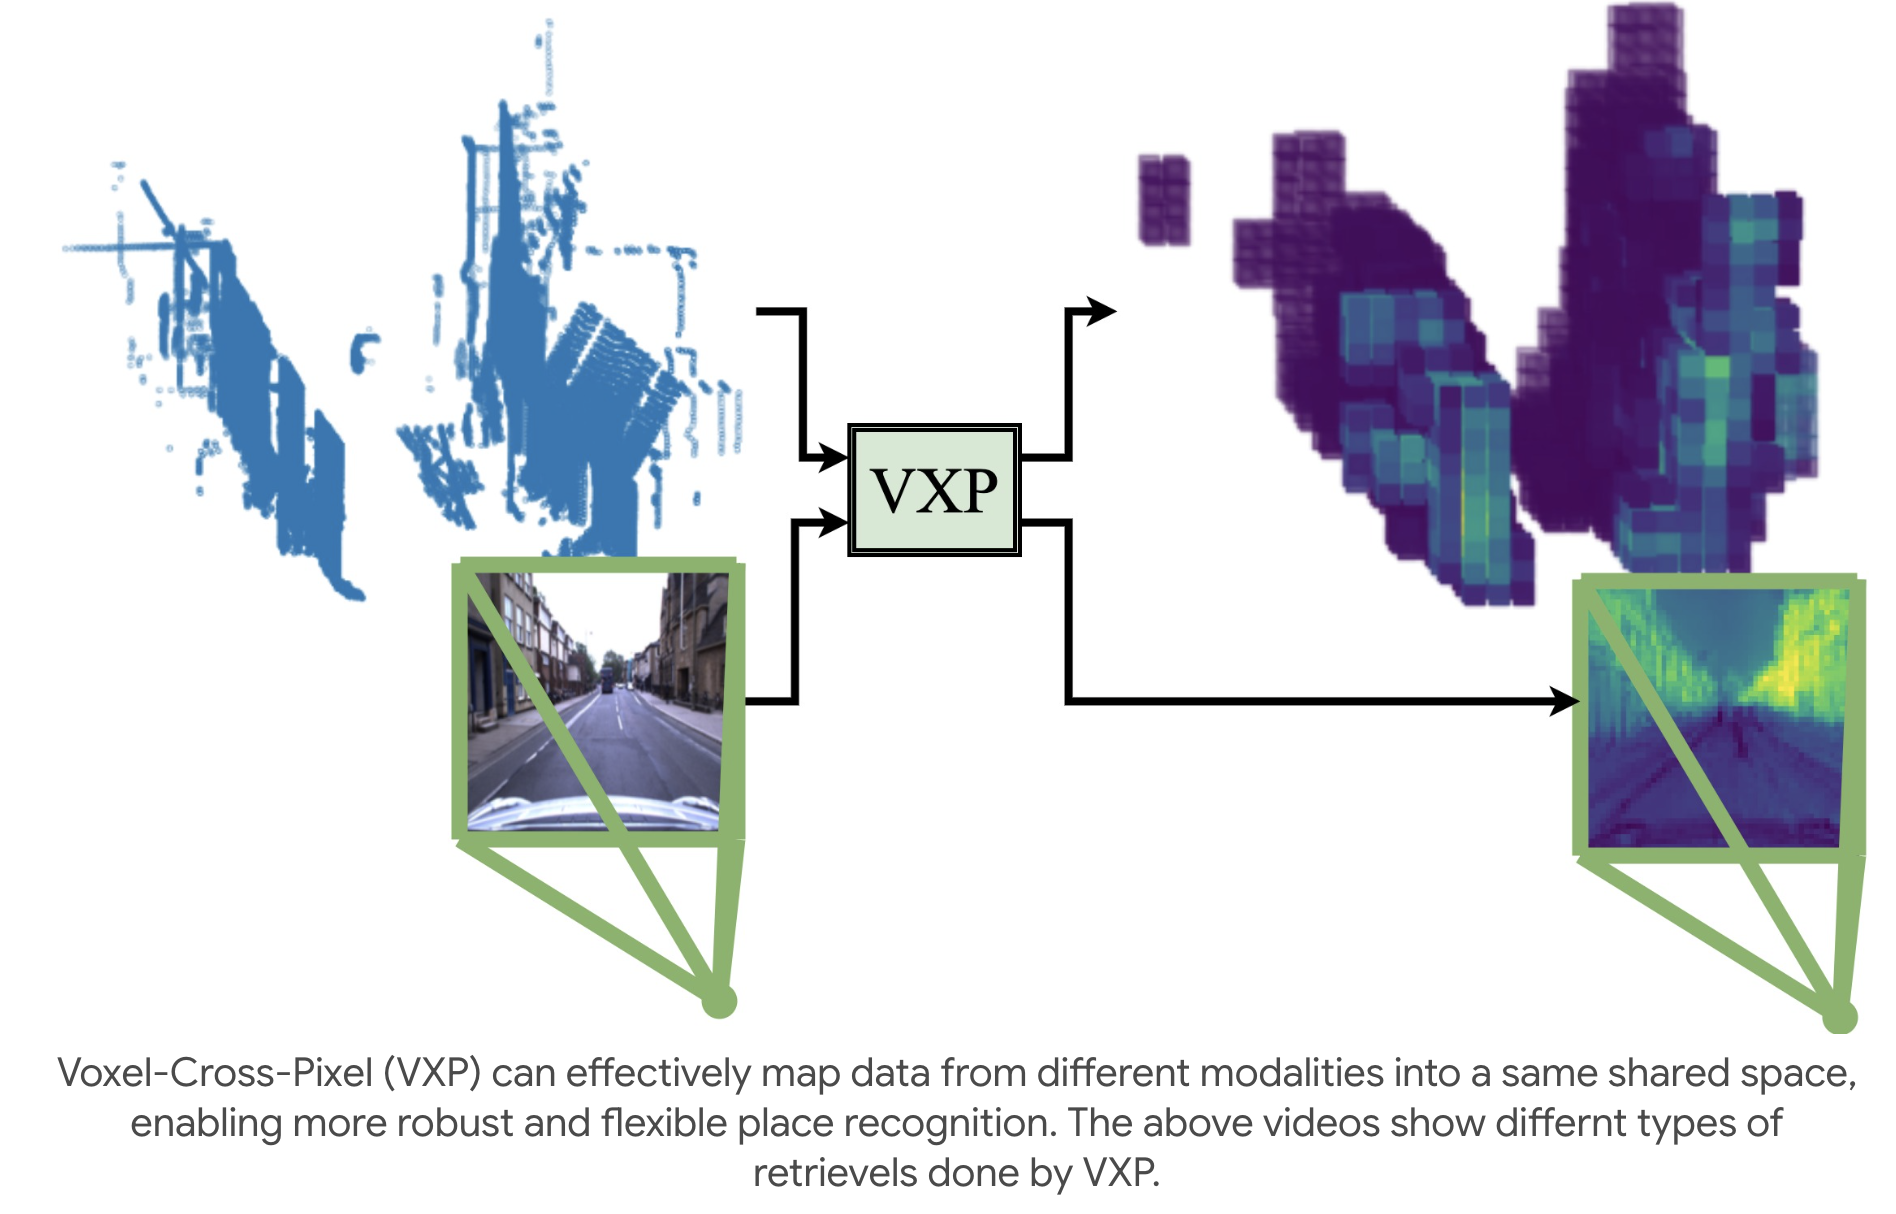
VXP: Voxel-Cross-Pixel Large-scale Image-LiDAR Place Recognition
Yun-Jin Li, Mariia Gladkova, Yan Xia, Rui Wang, Daniel Cremers
3DV, 2025
paper |
project page |
code
|
|
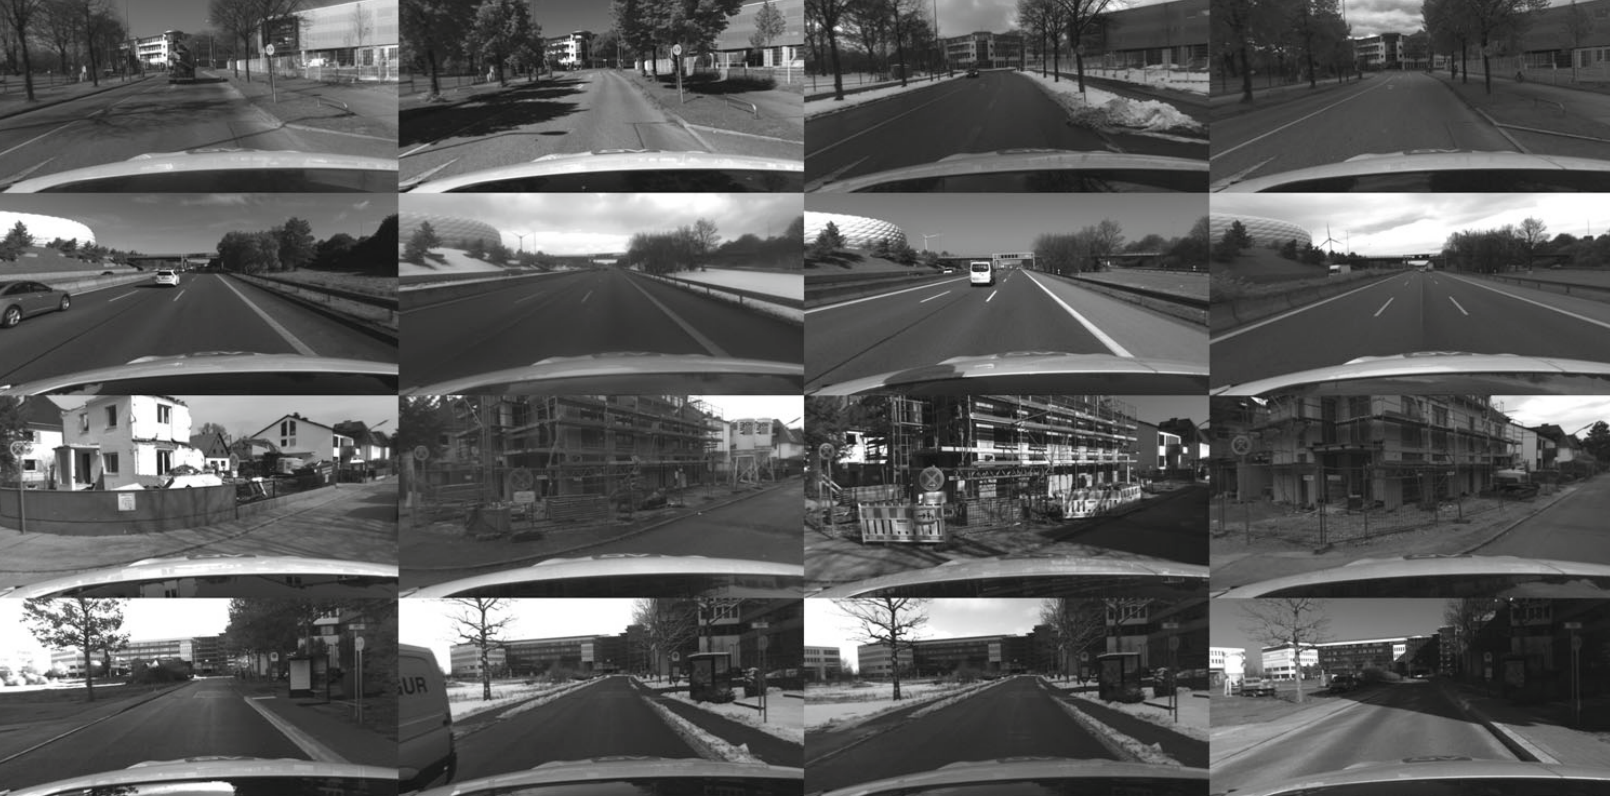
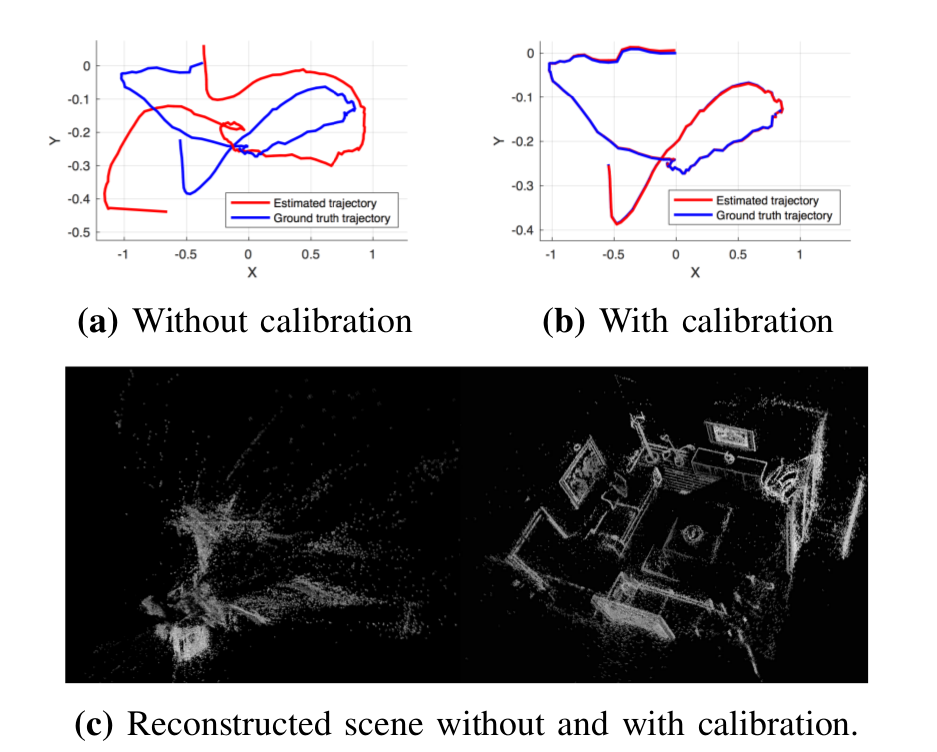
4Seasons: Benchmarking Visual SLAM and Long-Term Localization for Autonomous Driving in
Challenging Conditions
Patrick Wenzel, Nan Yang, Rui Wang, Niclas Zeller, Daniel Cremers
IJCV, 2024
paper
|
|
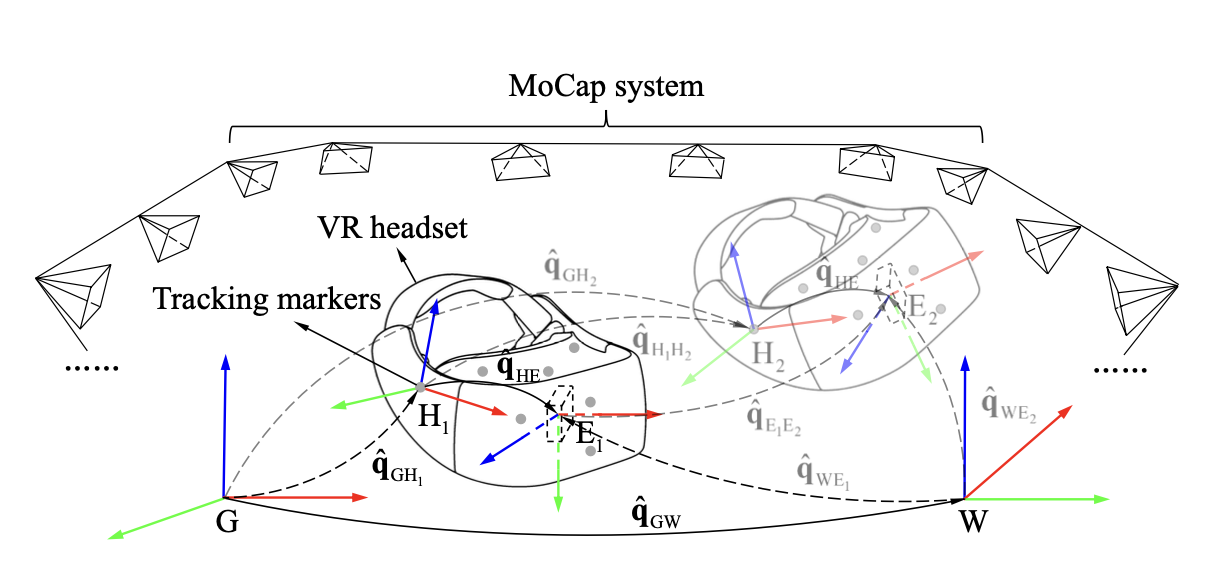
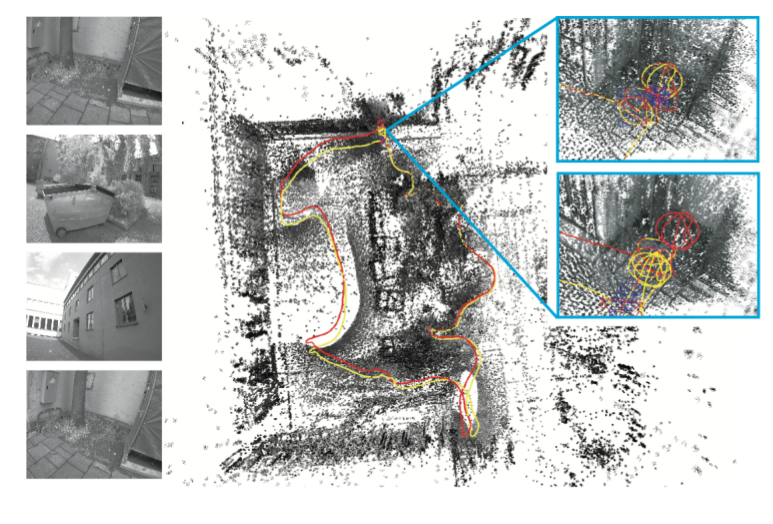
A Spatiotemporal Hand-Eye Calibration for Trajectory Alignment in Visual(-Inertial) Odometry
Evaluation
Zichao Shu, Lijun Li, Rui Wang, Zetao Chen
RA-L, 2024
paper
|
|
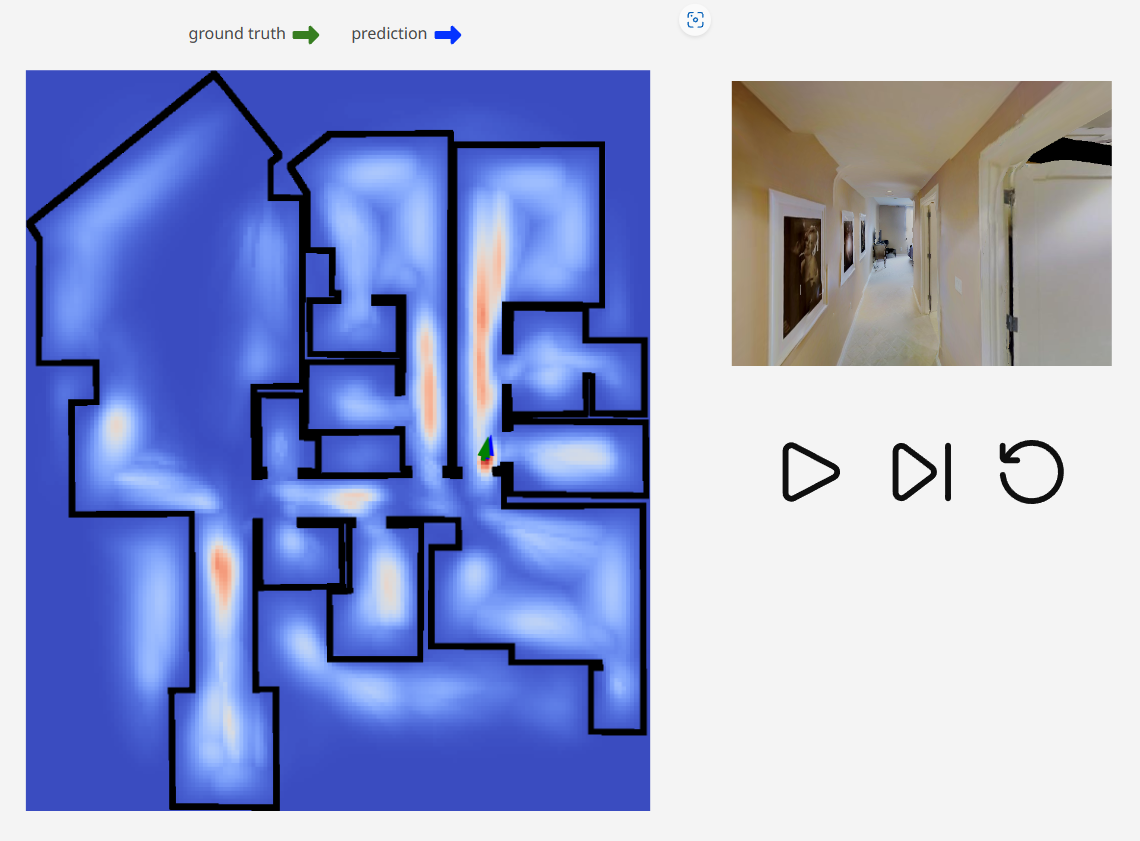
F3Loc: Fusion and Filtering for Floorplan Localization
Changan Chen, Rui Wang, Christoph Vogel, Marc Pollefeys
CVPR, 2024 (Highlight)
paper |
project page |
code |
dataset
|
|
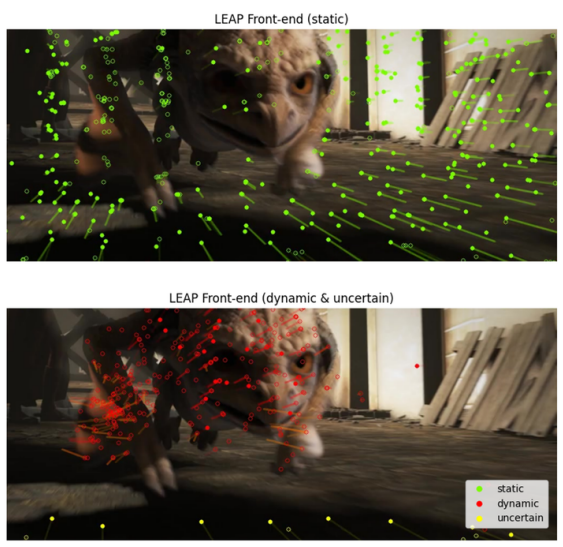
LEAP-VO: Long-term Effective Any Point Tracking for Visual Odometry
Weirong Chen, Le Chen, Rui Wang, Marc Pollefeys
CVPR, 2024
paper |
project page |
code
|
|
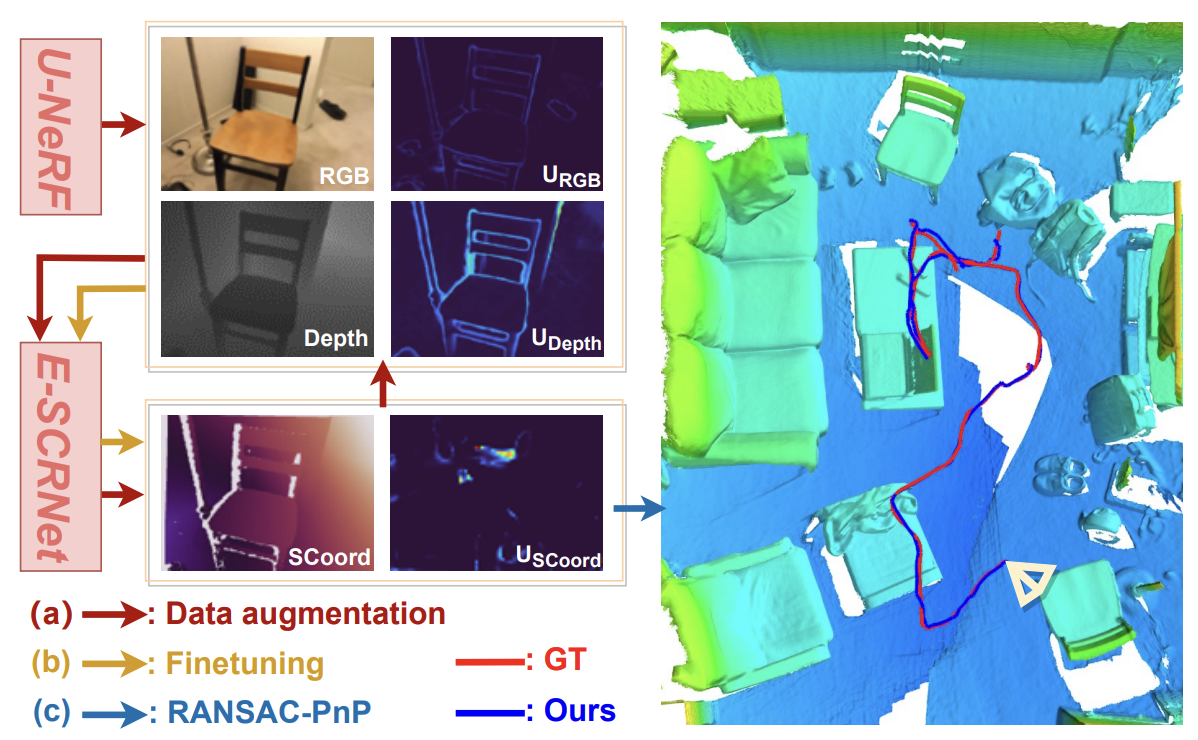
Leveraging Neural Radiance Fields for Uncertainty-Aware Visual Localization
Le Chen, Weirong Chen, Rui Wang, Marc Pollefeys
ICRA, 2024
paper |
video
|
|
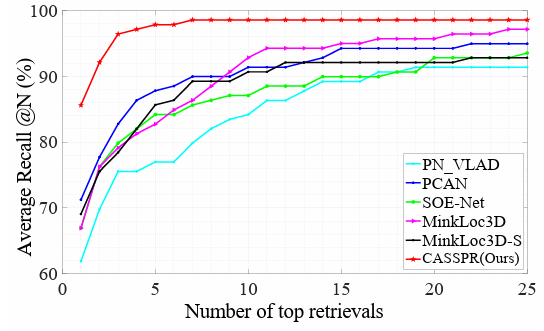
CASSPR: Cross Attention Single Scan Place Recognition
Yan Xia, Mariia Gladkova, Rui Wang, Qianyun Li, Uwe Stilla, Joao F Henriques, Daniel Cremers
ICCV, 2023
paper |
code
|
|
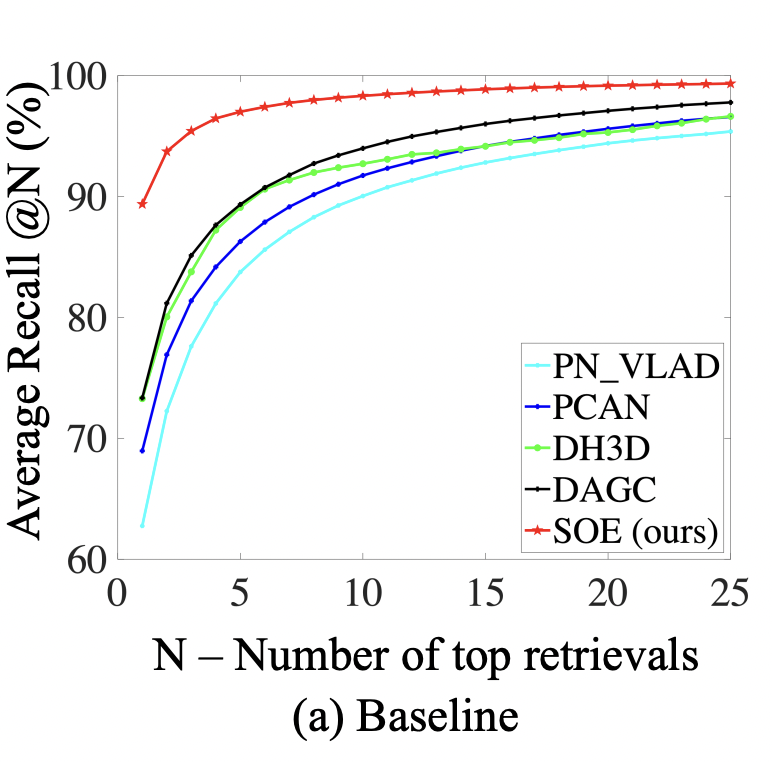
SOE-Net: A Self-Attention and Orientation Encoding Network for Point Cloud based Place
Recognition
Yan Xia, Yusheng Xu, Shuang Li, Rui Wang, Juan Du, Daniel Cremers, Uwe Stilla
CVPR, 2021 (Oral Presentation)
paper |
code
|
|
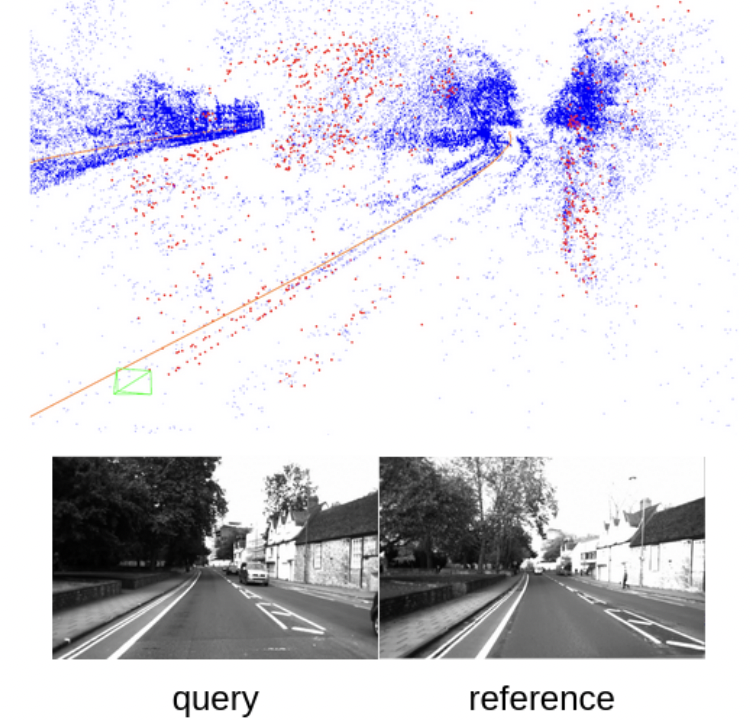
Tight Integration of Feature-based Relocalization in Monocular Direct Visual Odometry
Mariia Gladkova, Rui Wang, Niclas Zeller, Daniel Cremers
ICRA, 2021
paper |
project page |
video |
teaser video
|
|
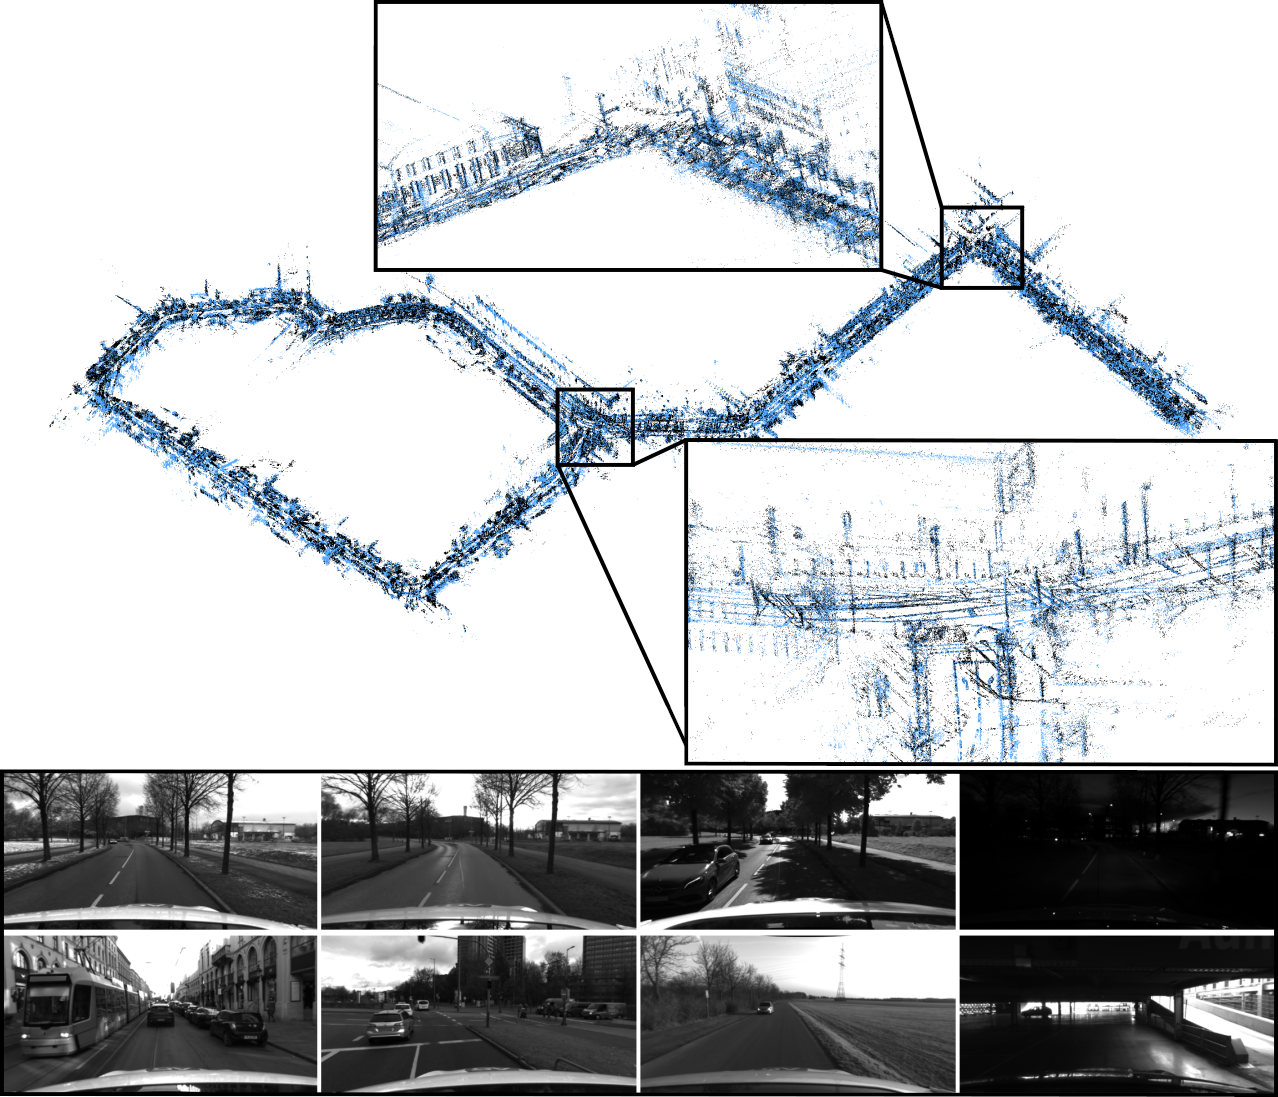
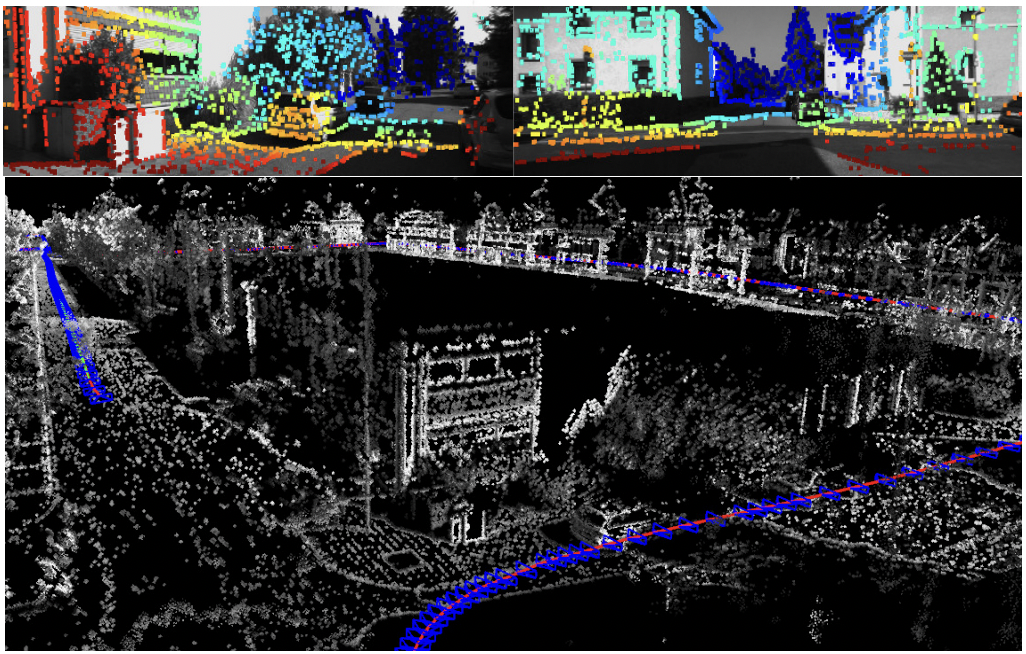
4Seasons: A Cross-Season Dataset for Multi-Weather SLAM in Autonomous Driving
Patrick Wenzel, Rui Wang, Nan Yang, Qing Cheng, Qadeer Khan,Lukas von Stumberg, Niclas
Zeller, Daniel Cremers
GCPR, 2020
paper |
project page |
dataset |
video
|
|
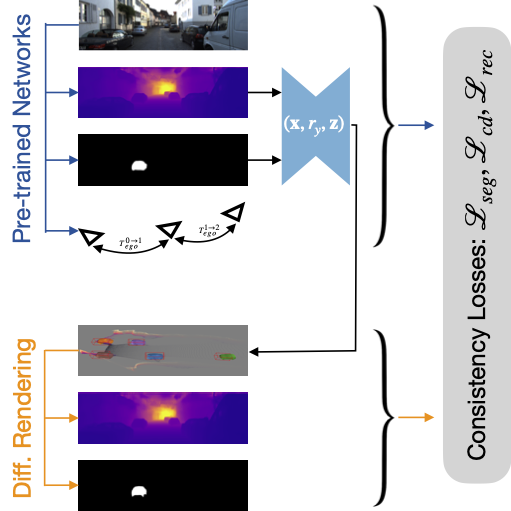
Learning Monocular 3D Vehicle Detection without 3D Bounding Box Labels
Lukas Koestler, Nan Yang, Rui Wang, Daniel Cremers
GCPR, 2020
paper |
supplement |
project page |
data |
video |
teaser video
|
|
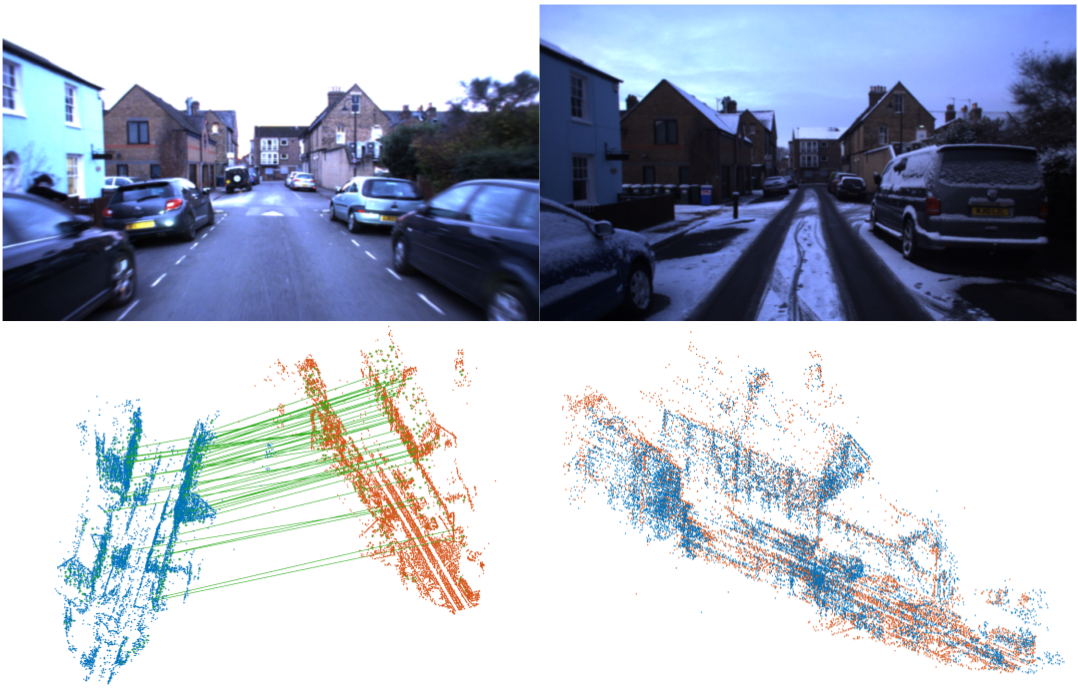
DH3D: Deep Hierarchical 3D Descriptors for Robust Large-Scale 6DoF Relocalization
Juan Du*, Rui Wang*, Daniel Cremers
ECCV, 2020 (*equal contribution) (Spotlight
Presentation)
paper |
supplement |
project page |
code |
data |
video |
teaser video
|
|
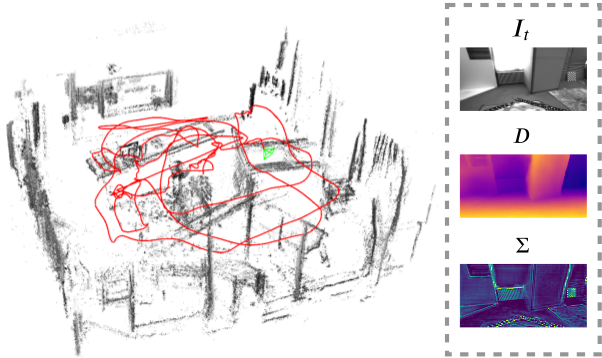
D3VO: Deep Depth, Deep Pose and Deep Uncertainty for Monocular Visual Odometry
Nan Yang, Lukas von Stumberg, Rui Wang, Daniel Cremers
CVPR, 2020 (Oral Presentation)
paper & supplement |
project page |
video
|
|
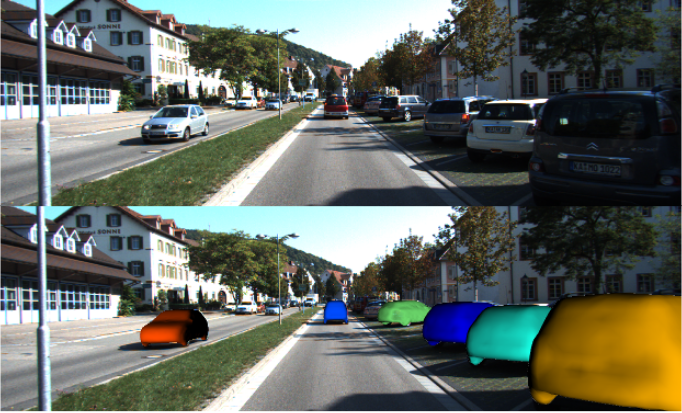
DirectShape: Photometric Alignment of Shape Priors for Visual Vehicle Pose and Shape Estimation
Rui Wang, Nan Yang, Joerg Stueckler, Daniel Cremers
ICRA, 2020
paper |
supplement |
project page |
video |
presentation
|
|
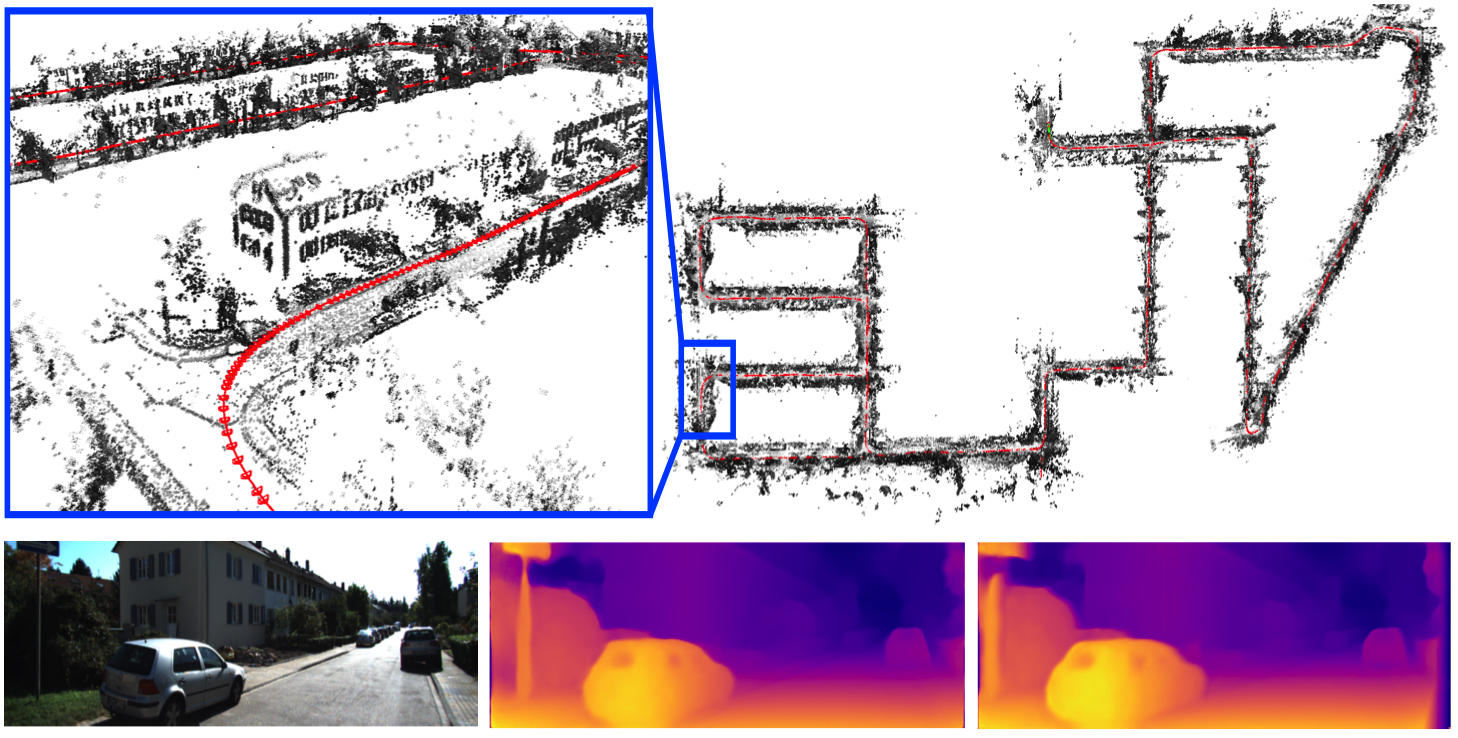
Deep Virtual Stereo Odometry: Leveraging Deep Depth Prediction for Monocular Direct Sparse
Odometry
Nan Yang, Rui Wang, Joerg Stueckler, Daniel Cremers
ECCV, 2020 (Oral Presentation)
paper |
supplement |
project page |
video |
presentation
|
|
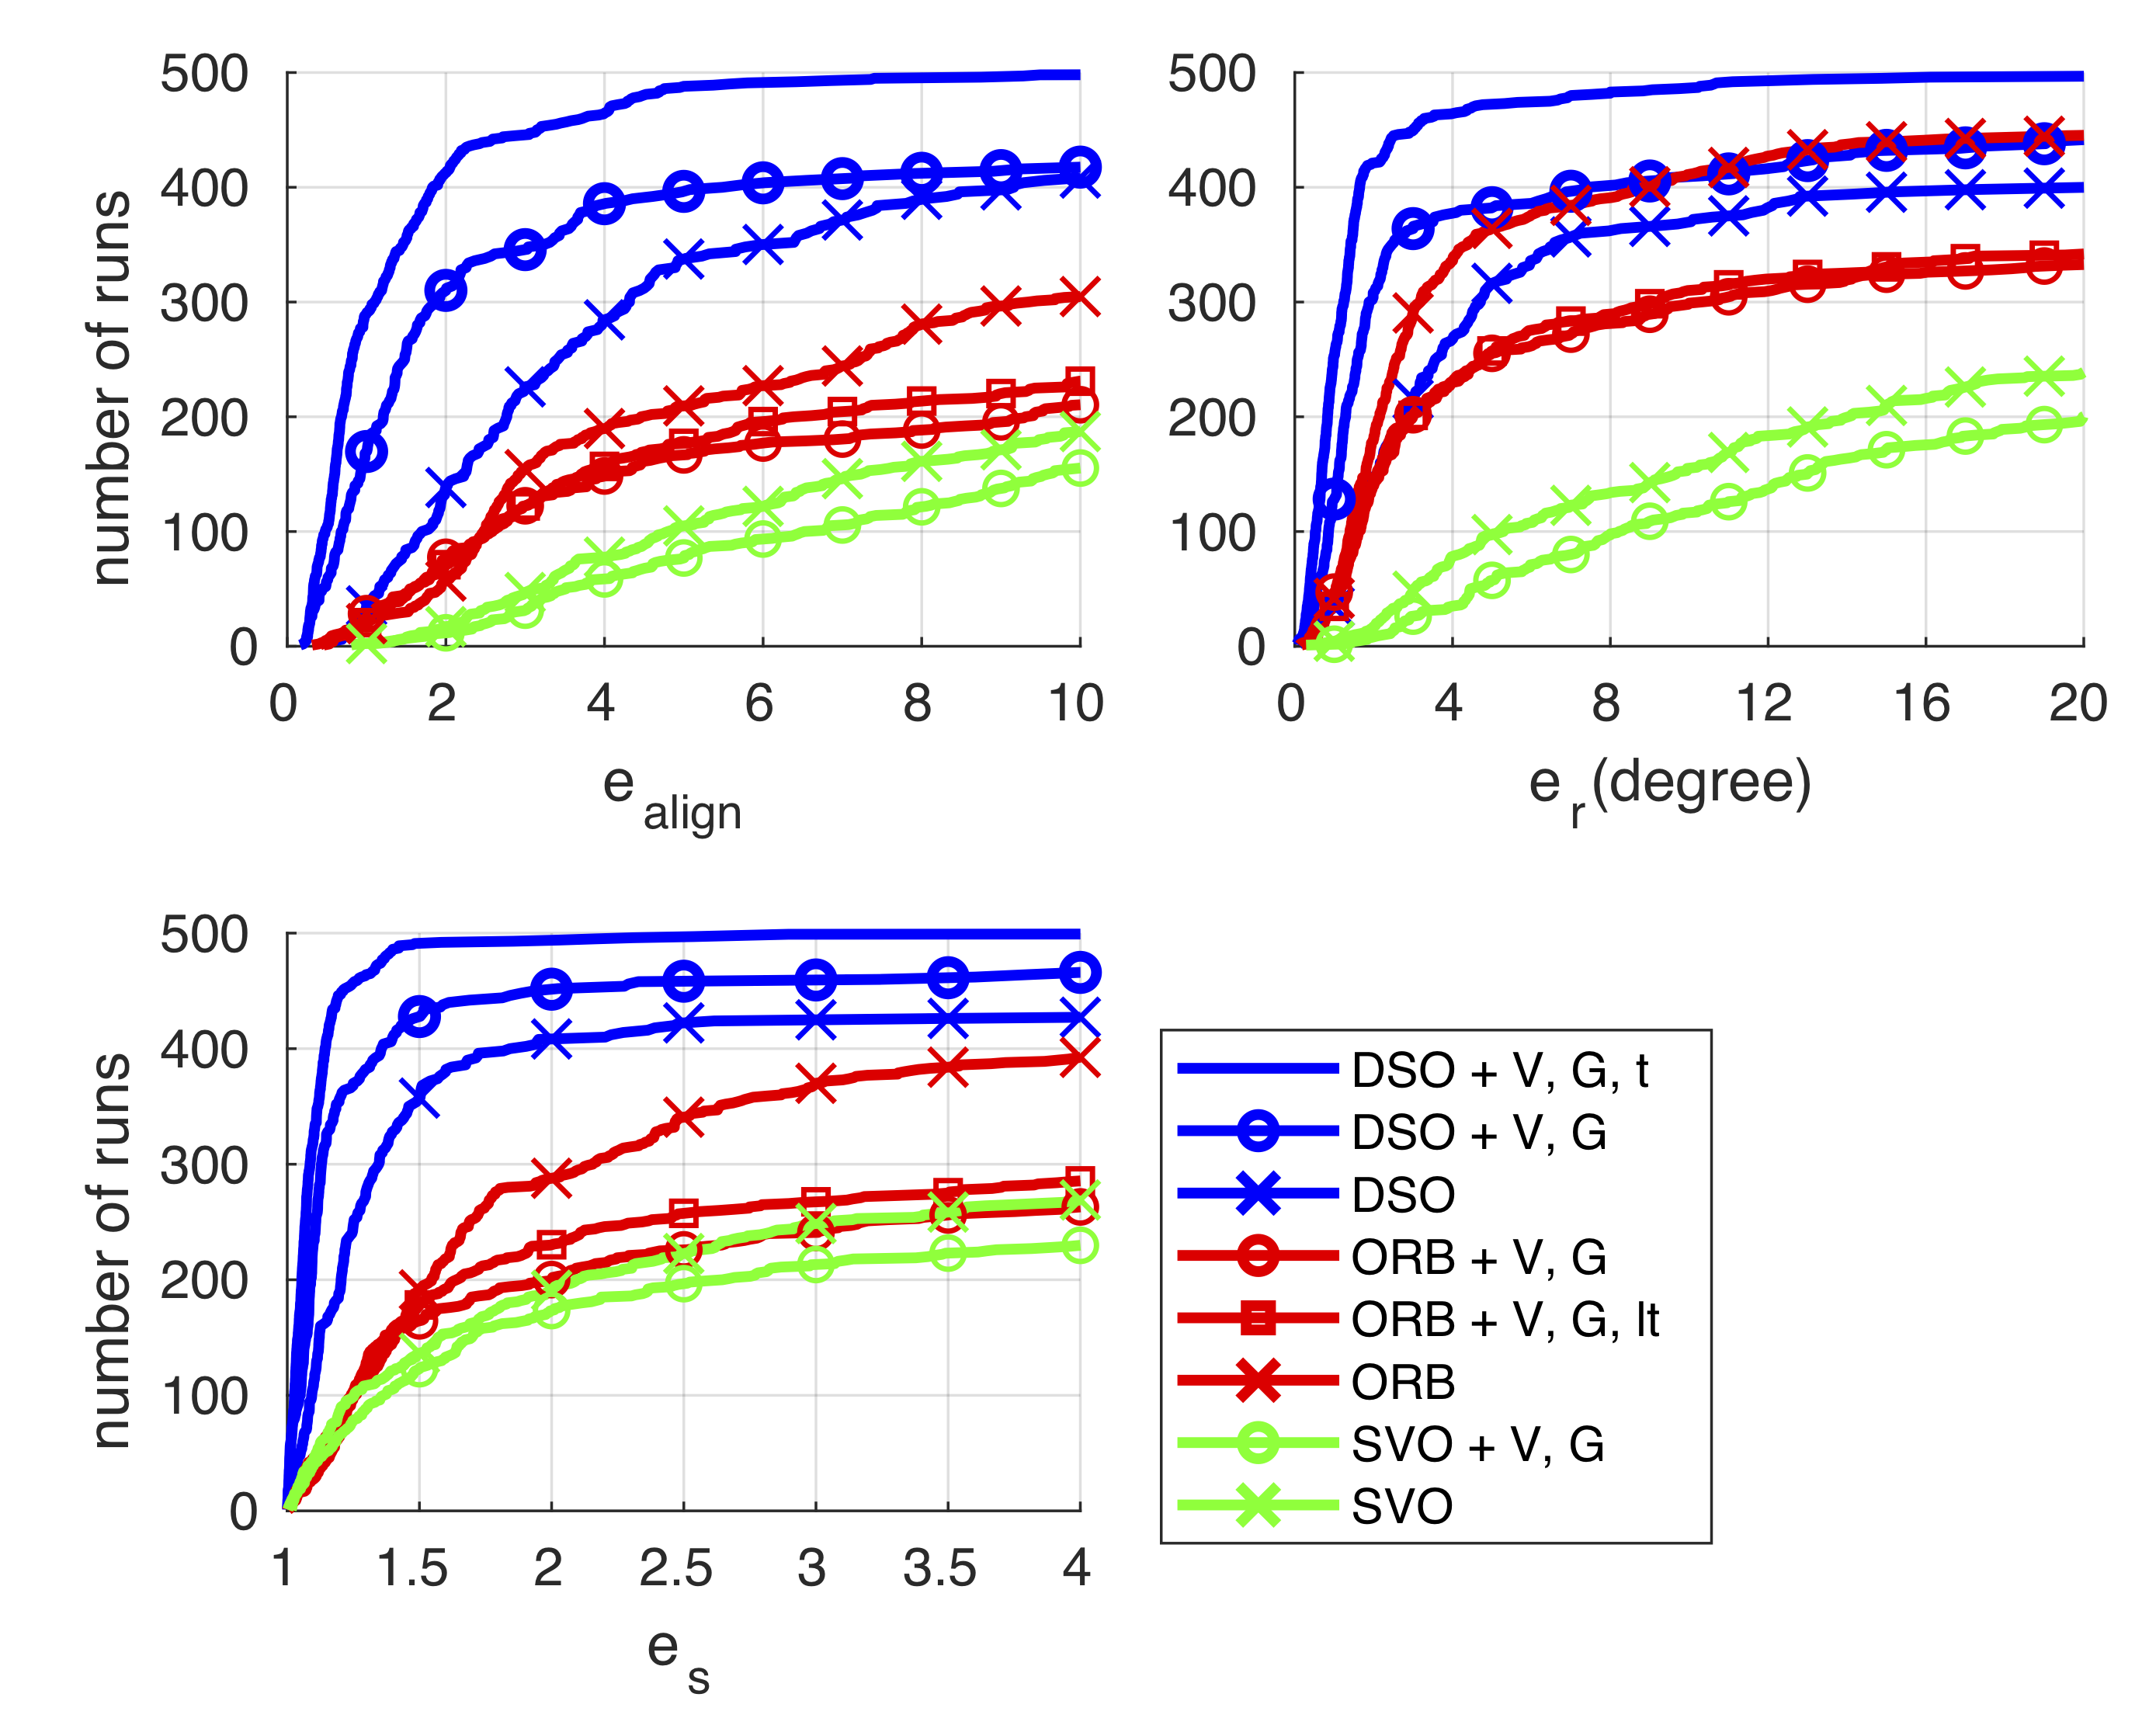
Challenges in Monocular Visual Odometry: Photometric Calibration, Motion Bias and Rolling
Shutter Effect
Nan Yang*, Rui Wang*, Xiang Gao, Daniel Cremers
RA-L and IROS, 2018 (*equal contribution)
paper
|
|
LDSO: Direct Sparse Odometry with Loop Closure
Xiang Gao, Rui Wang, Nikolaus Demmel, Daniel Cremers
IROS, 2018
paper |
project page |
video |
code
|
|
Online Photometric Calibration of Auto Exposure Video for Realtime Visual Odometry and SLAM
Paul Bergmann, Rui Wang, Daniel Cremers
RA-L and ICRA, 2018 (Best Vision Paper Award - Finalist)
paper |
project page |
video |
code
|
|
Stereo DSO: Large-Scale Direct Sparse Visual Odometry with Stereo Cameras
Rui Wang*, Martin Schwoerer*, Daniel Cremers
ICCV, 2017 (*equal contribution)
paper |
supplement |
project page |
video (VO) |
video (SLAM)
|
Patents
-
Spatial Recall from Videos
Rui Wang, Ondrej Miksik, Enric Galceran Yebenes, Marc Pollefeys
US Patent App. 18/959,860, 2026
-
Image sequence trajectories for visual odometry
Rui Wang, Marc Pollefeys, Weirong Chen
US Patent 12,711,636, 2025
-
Visual localization
Rui Wang, Christoph Vogel, Marc Pollefeys
US Patent App. 18/420,753, 2025
-
Generating images for neural network training
Rui Wang, Le Chen, Marc Pollefeys
US Patent 12,488,571, 2025
-
Matching between 2D and 3D for direct localization
Johannes Schönberger, Rui Wang, Prune Truong, Marc Pollefeys
US Patent App. 18/055,722, 2024
-
Deep virtual stereo odometry
Nan Yang, Rui Wang
US Patent 11,064,178, 2021
|
|
Academic Services
Conference reviewer
CVPR, ICCV, ECCV, NeurIPS, ICLR, ICML, ICRA, IROS, AAAI, 3DV
Journal reviewer
RA-L, T-RO, AURO, TMM, P&RS, Pattern Recognition, IJRR
Organizer
ECCV 2020 Workshop on Map-based Localization for
Autonomous Driving
|
|